Third Wave Automation
Head of Perception and Manipulation
I led Perception and Manipulation on Third Wave's autonomous forklift platform, from pallet detection and pose estimation to barcode scanning and the vehicle's state machine.
I'm a machine learning researcher and engineer working on interesting problems that need real-world solutions. Right now I'm at Apple, producing the most visually accurate and detailed maps in the world. Before that I built the vision stack for autonomous forklifts at Third Wave Automation. During my Ph.D. I studied computer vision and machine learning at the University of Washington, working on embodied agents, representation learning, and anything else I found interesting.
Head of Perception and Manipulation
I led Perception and Manipulation on Third Wave's autonomous forklift platform, from pallet detection and pose estimation to barcode scanning and the vehicle's state machine.
Daniel Gordon, Kiana Ehsani, Dieter Fox + 1 more
arXiv 2020
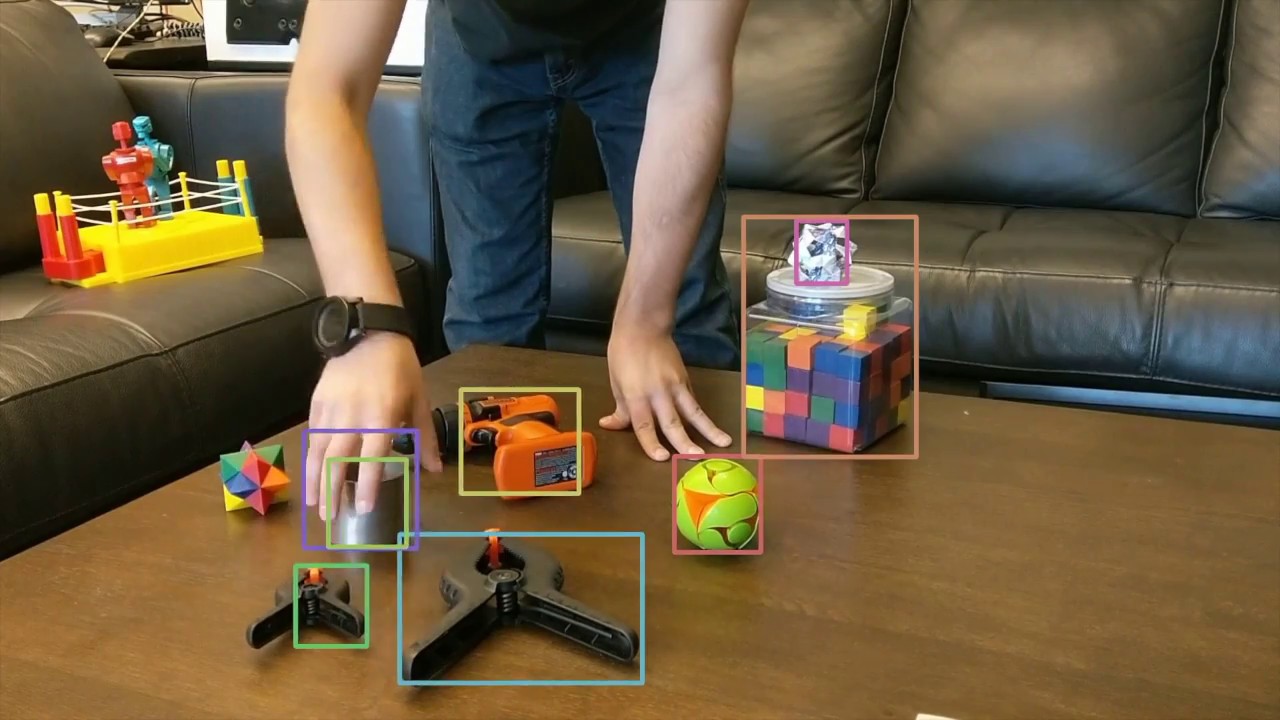
Videos provide a free source of semantically meaningful temporal labels, and Video Noise Contrastive Estimation uses that signal to learn robust image representations that outperform supervised ImageNet pretraining with similar dataset sizes.
Mohit Shridhar, Jesse Thomason, Daniel Gordon + 5 more
CVPR 2020
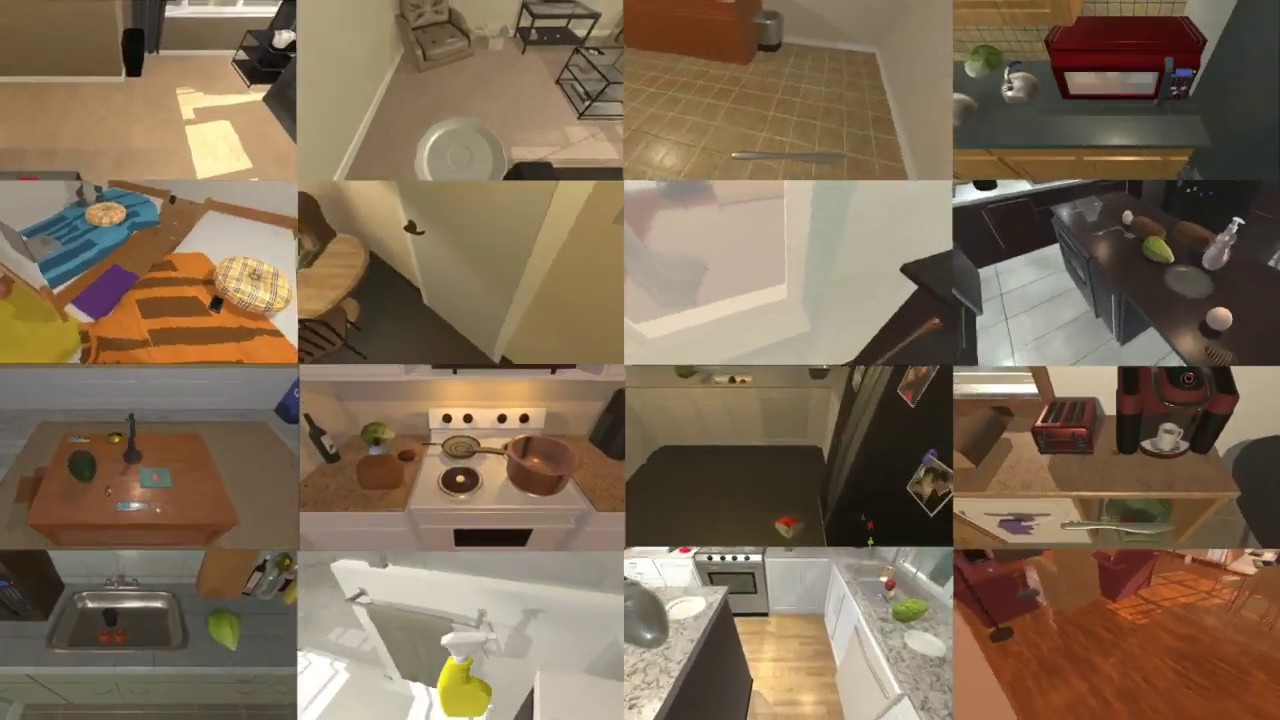
ALFRED maps natural-language instructions and egocentric vision to action sequences for household tasks, from 25k expert demonstrations in interactive environments.
Daniel Gordon, Ali Farhadi, Dieter Fox
RA-L 2018
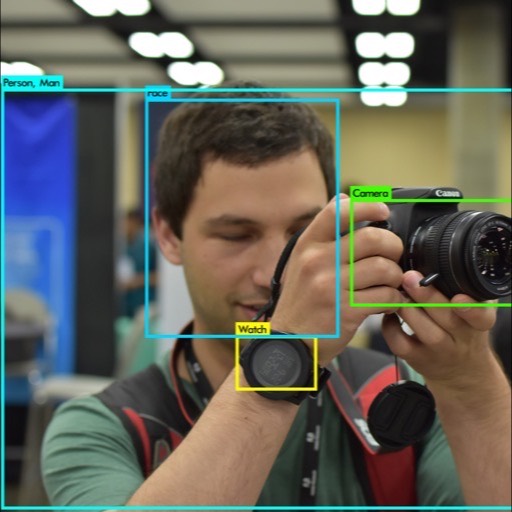
We develop a real-time generic deep object tracker that uses an LSTM to update its appearance model on the fly in one forward pass, tracking at 150 FPS.
Senior Machine Learning Engineer
I work on the Detailed City Experience, which upgrades the maps from a flat low-detail view to an immersive, highly detailed one. Using high resolution imagery we extract 3D road shape and features like lane markings, crosswalks and medians, and even painted color areas like bike lanes all at centimeter accuracy. Alongside that we build tree and building data for a rich 3D experience.
Head of Perception and Manipulation
I led the Perception and Manipulation team, which covered everything from detecting pallets and payloads and estimating their sizes, weights, and poses, autonomously scanning barcodes, critical safety features, and even managing the forklift's internal state machine and its interface with the warehouse management system. Over my four years the scope grew from individual perception contributions, to tech lead for the core perception product, to managing a team of five engineers.
Ph.D. in Computer Science
B.S. in Computer Science, Second Major in Entrepreneurship