Apple Maps 3DV
Senior Machine Learning Engineer
I build the models behind Apple's Detailed City Experience: segmentation, detection and diffusion over street imagery, and pixel-to-vectorized-3D-map models.
Apr 2024 - Present
Senior Machine Learning Engineer
I build the models behind Apple's Detailed City Experience: segmentation, detection and diffusion over street imagery, and pixel-to-vectorized-3D-map models.
Head of Perception and Manipulation
I led Perception and Manipulation on Third Wave's autonomous forklift platform, from pallet detection and pose estimation to barcode scanning and the vehicle's state machine.
Kiana Ehsani, Daniel Gordon, Thomas Nguyen + 2 more
ICLR 2021
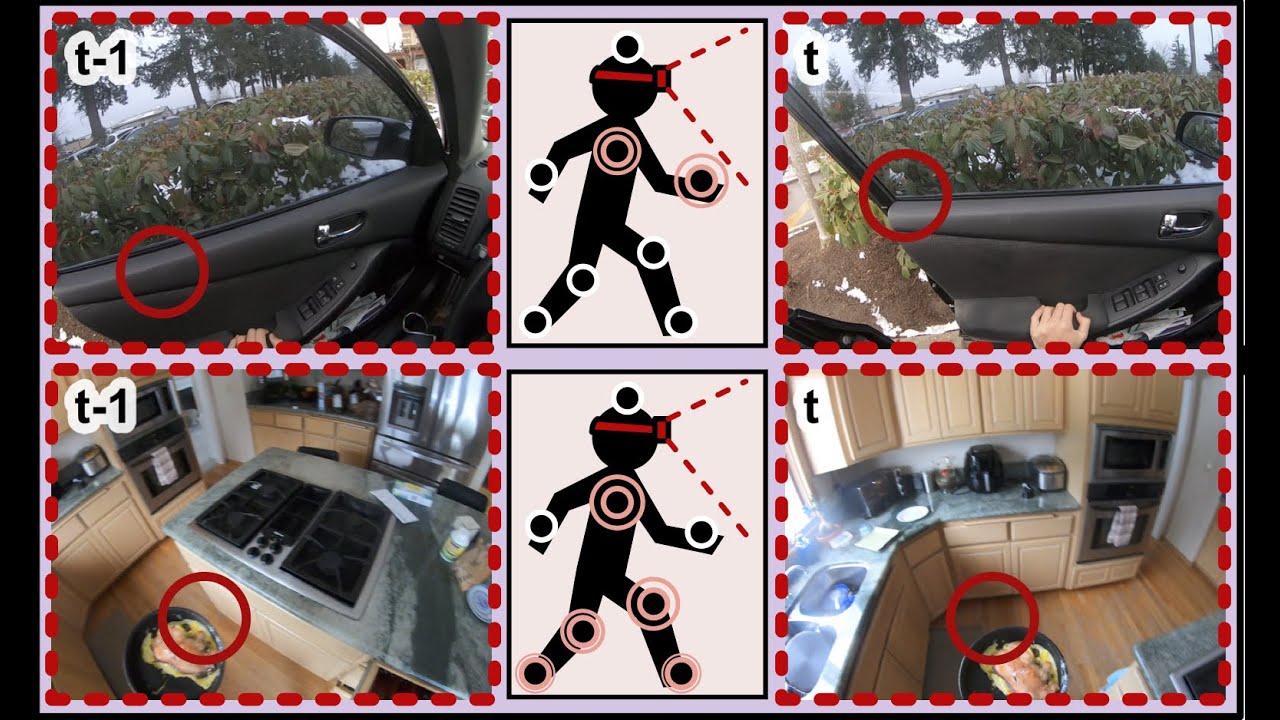
A visual representation learned from unlabeled human interaction video, where gaze and IMUs provide the labels as opposed to human-made annotations to learn human-centric representations.
Daniel Gordon
Ph.D. Thesis 2020
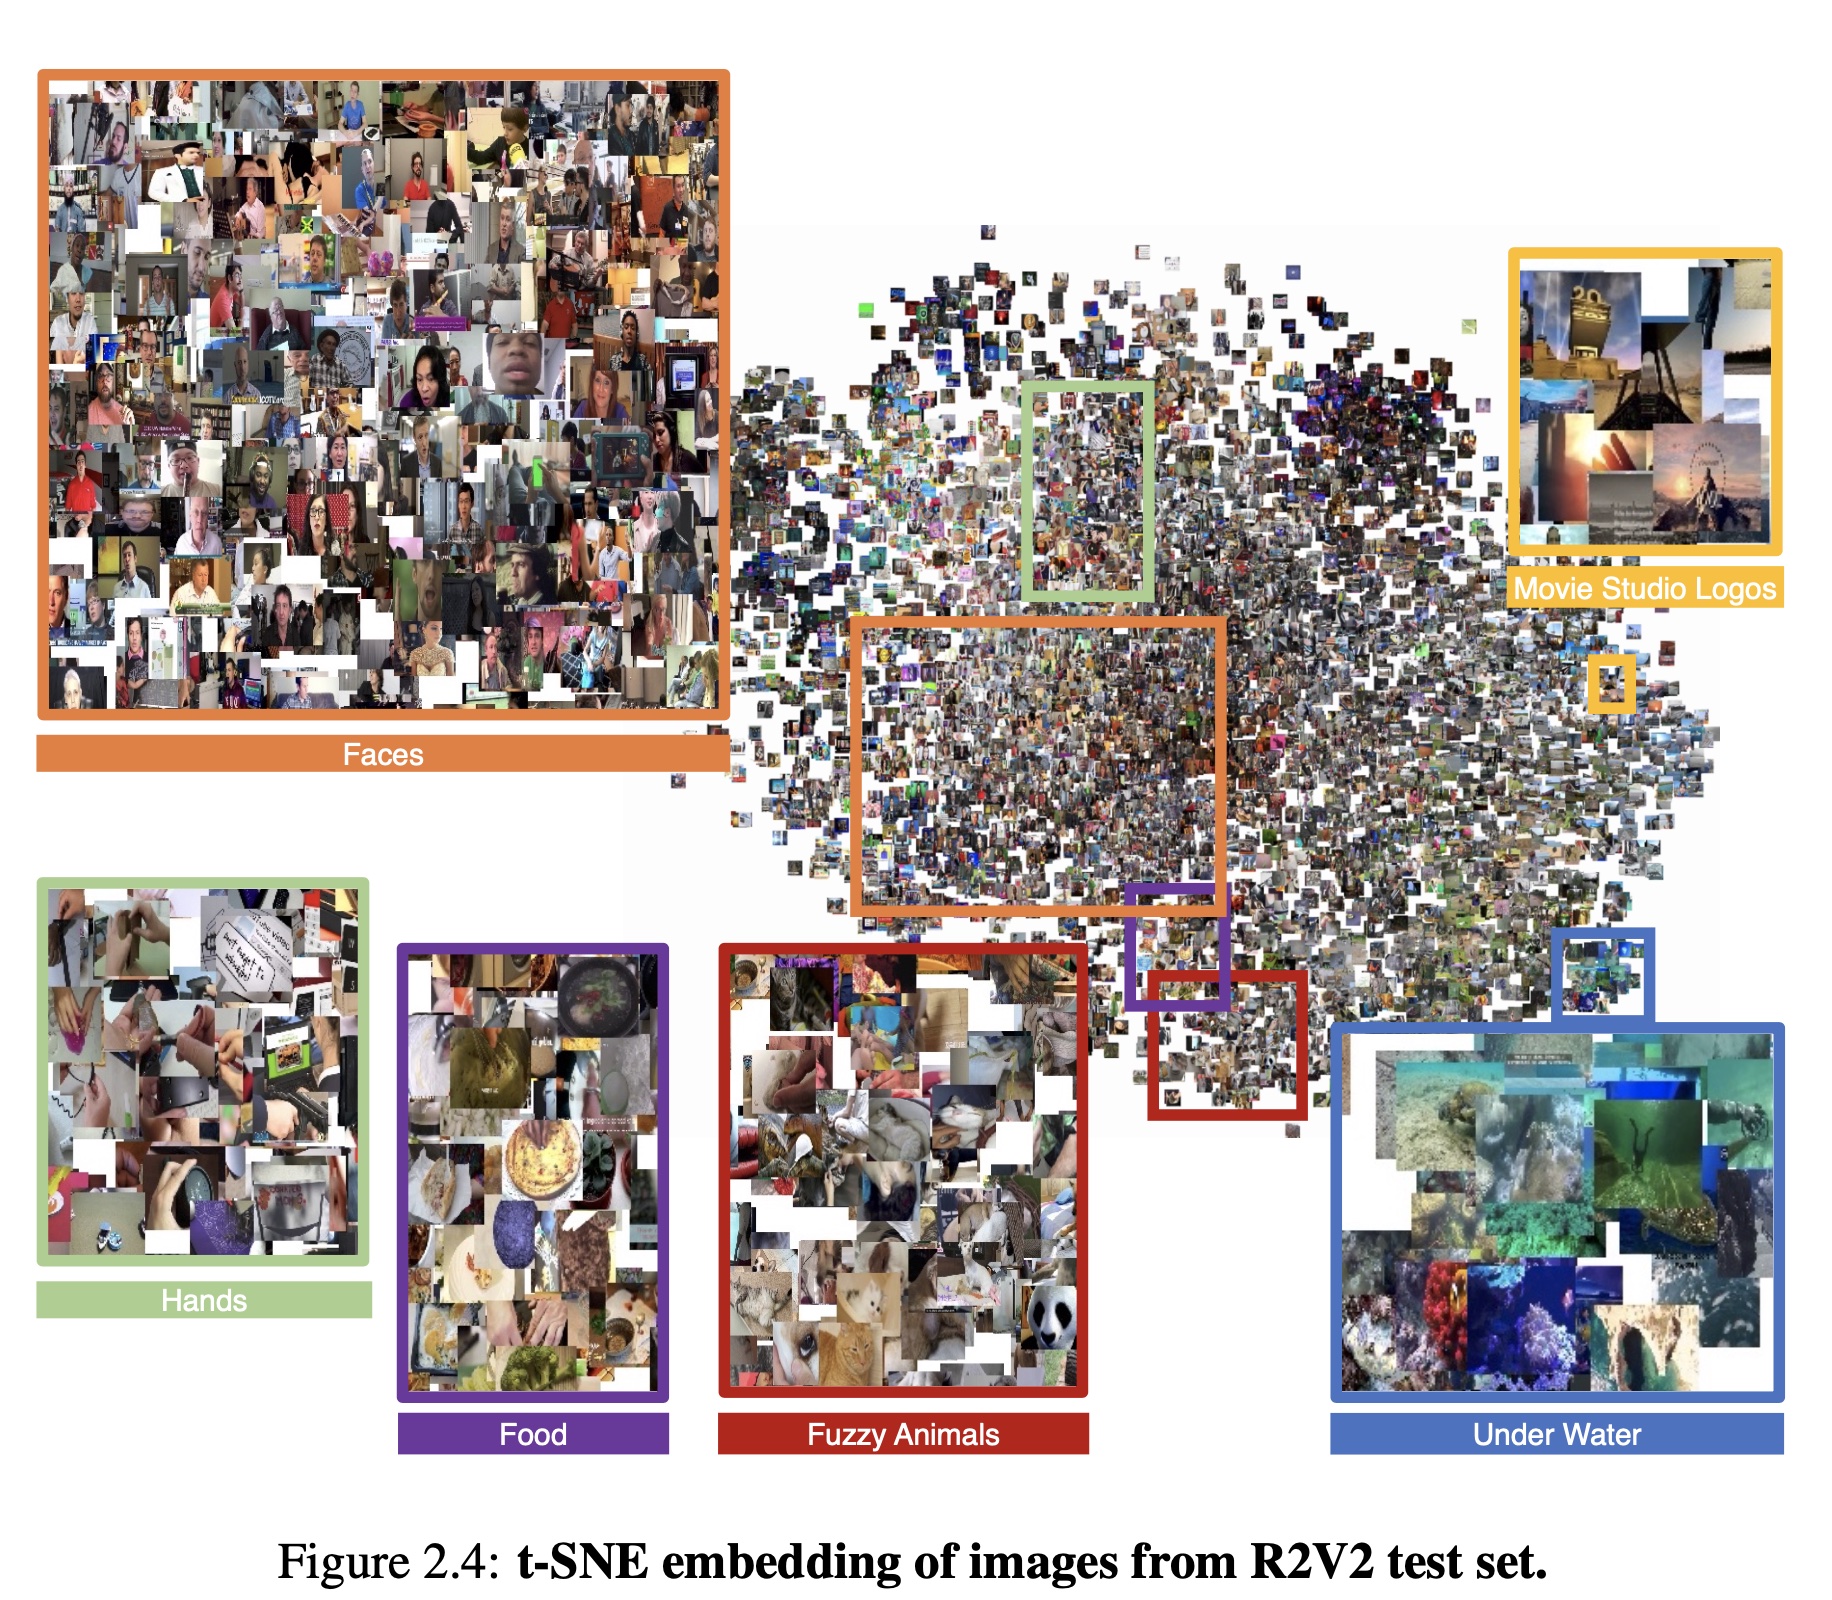
My PhD thesis, on learning visual representations from videos and embodied agents.

Daniel Gordon, Kiana Ehsani, Dieter Fox + 1 more
arXiv 2020
Videos provide a free source of semantically meaningful temporal labels, and Video Noise Contrastive Estimation uses that signal to learn robust image representations that outperform supervised ImageNet pretraining with similar dataset sizes.
Ali Farhadi, Daniel Gordon, Aaron Walsman + 8 more
I was head TA for the University of Washington's Introduction to Deep Learning course, creating homeworks in a from-scratch Pytorch-autograd-style neural network library pure Python, NumPy, and Numba.
Mohit Shridhar, Jesse Thomason, Daniel Gordon + 5 more
CVPR 2020
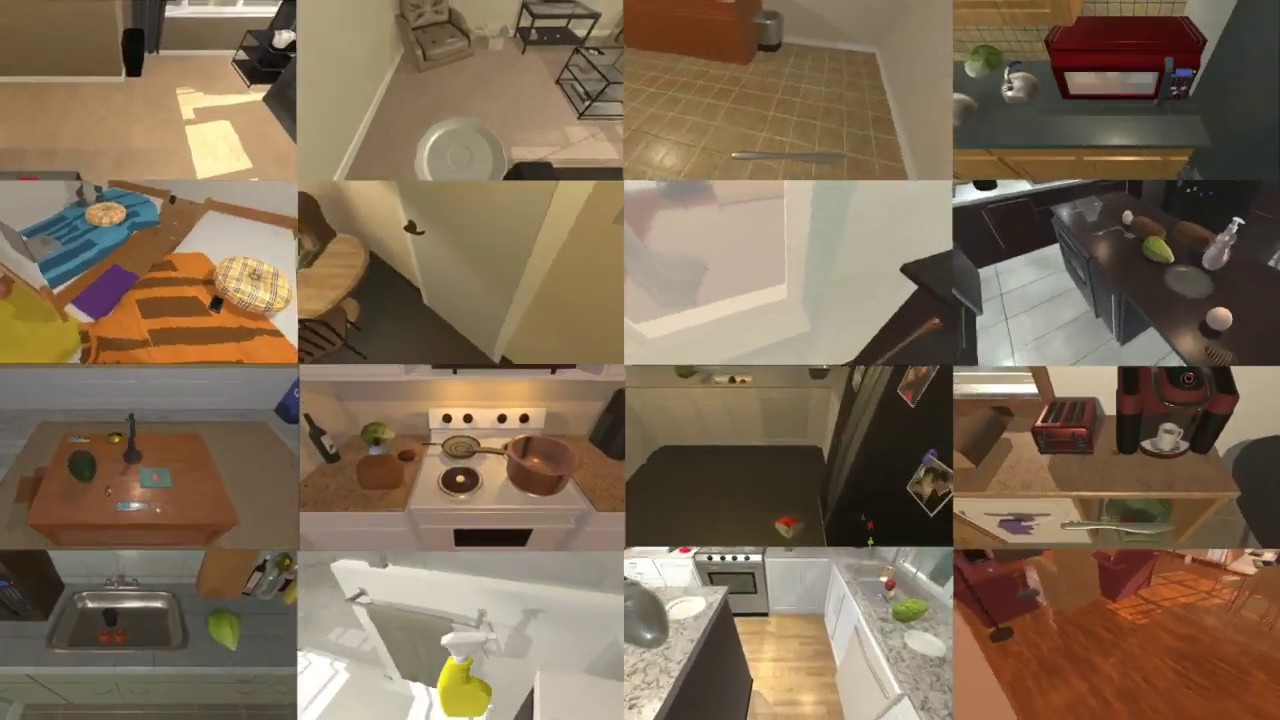
ALFRED maps natural-language instructions and egocentric vision to action sequences for household tasks, from 25k expert demonstrations in interactive environments.
Daniel Gordon, Abhishek Kadian, Devi Parikh + 2 more
ICCV 2019
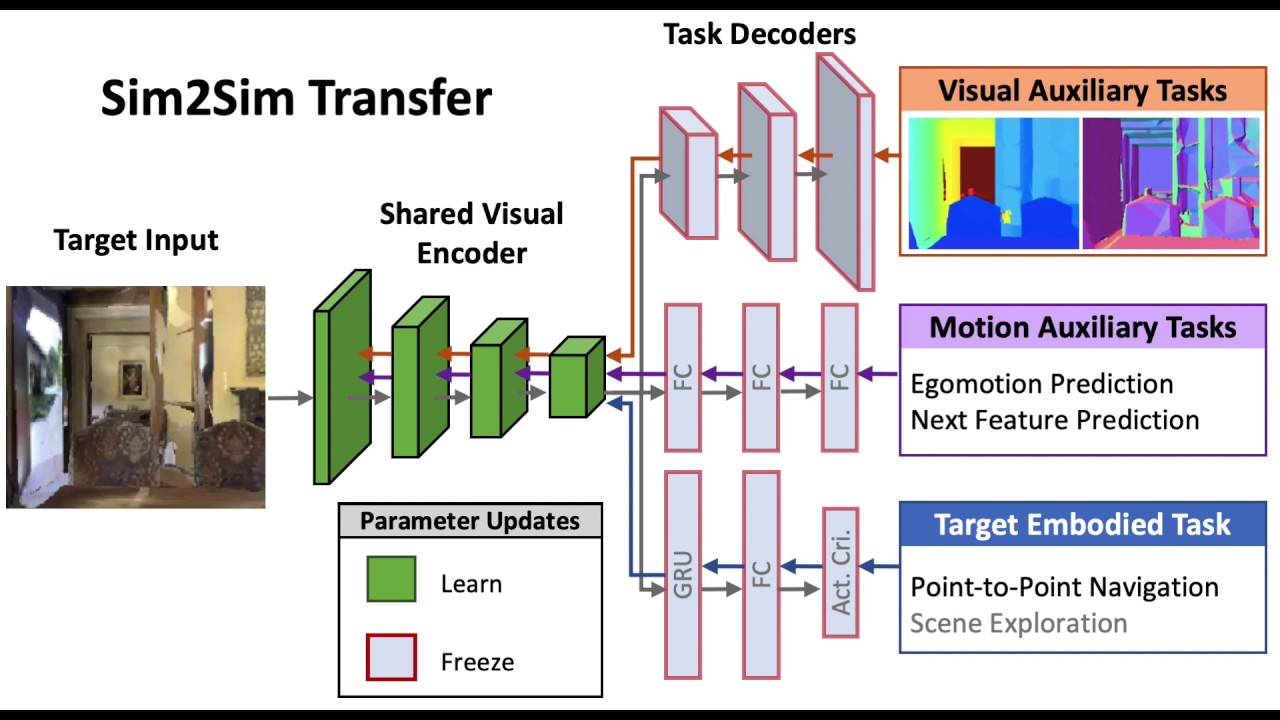
SplitNet decouples perception from policy learning, transferring between simulators and generalizing to unseen environments faster than end-to-end baselines.
Jesse Thomason, Daniel Gordon, Yonatan Bisk
NAACL 2019
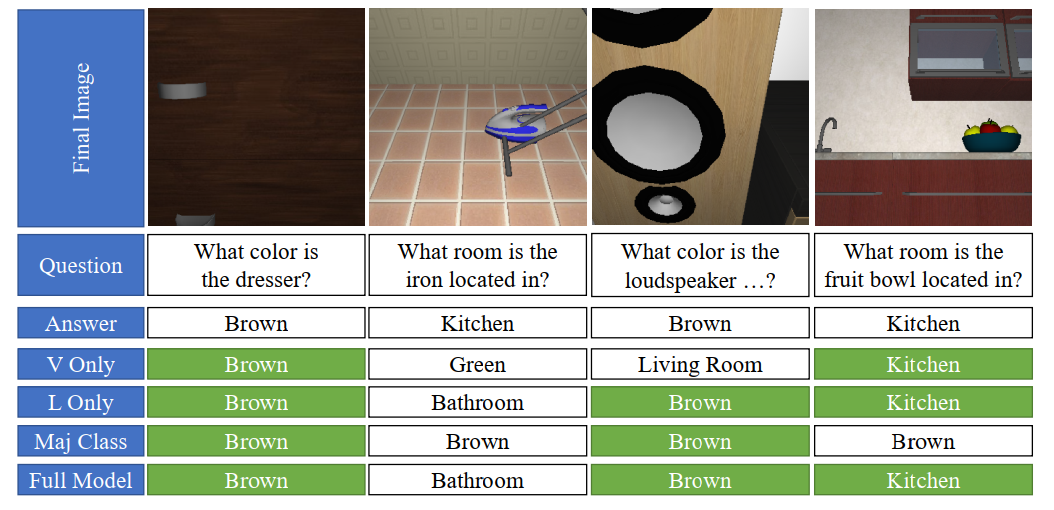
Unimodal baselines beat the random and majority-class ones typically reported, by up to 29% absolute, and are the right comparison for multimodal claims.
Daniel Gordon, Dieter Fox, Ali Farhadi
arXiv 2018
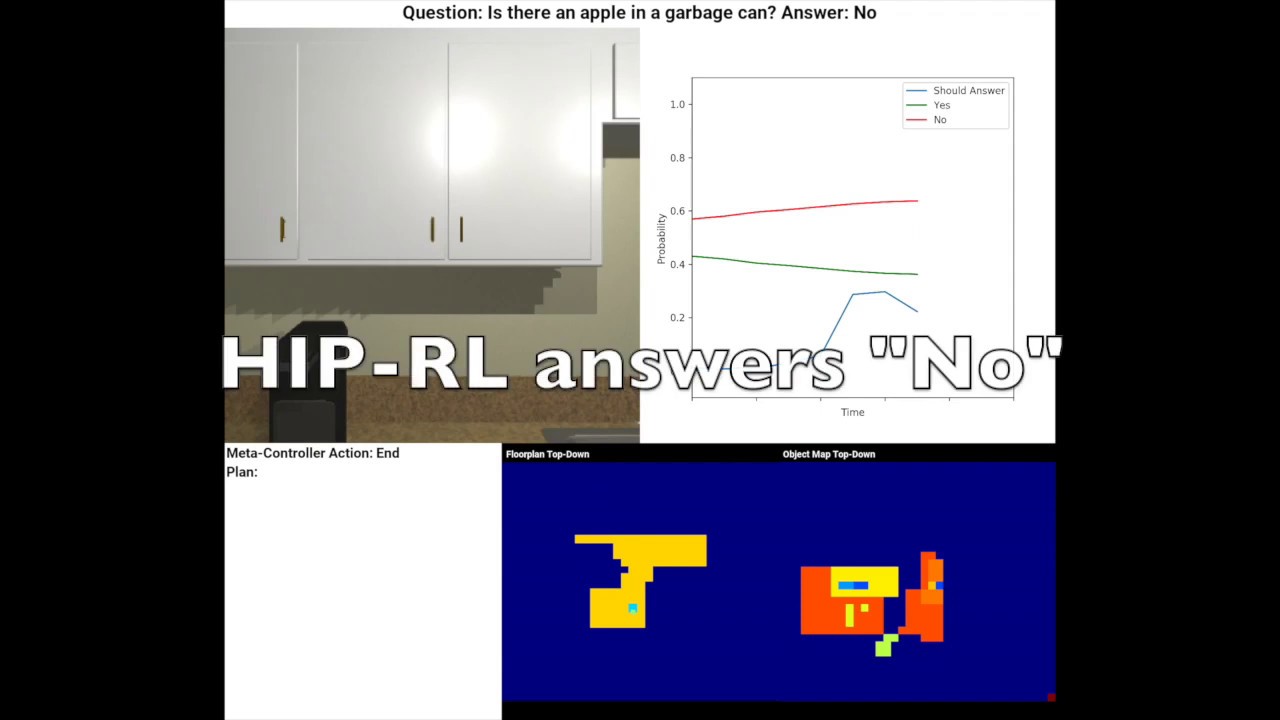
HIP-RL merges hierarchical symbolic planning with deep reinforcement learning, reaching state-of-the-art results on three datasets with fewer test-time steps.
Daniel Gordon
2018
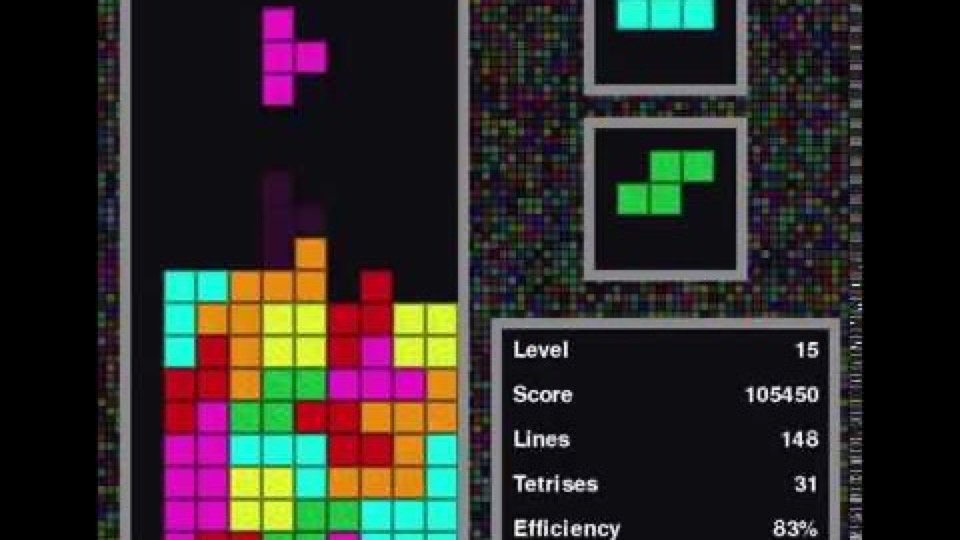
An RL agent trained end-to-end to play Tetris discovers super-human policies, planning many moves ahead rather than greedily clearing what is available.
Daniel Gordon, Ali Farhadi, Dieter Fox
RA-L 2018
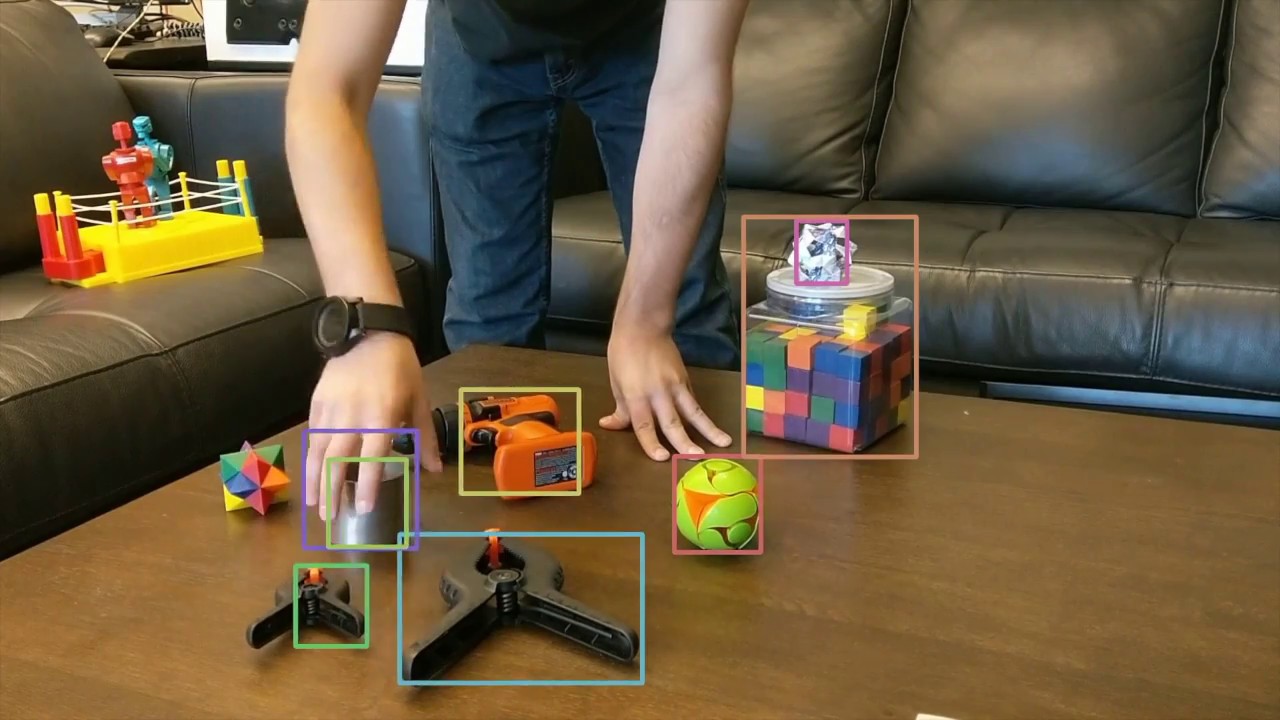
We develop a real-time generic deep object tracker that uses an LSTM to update its appearance model on the fly in one forward pass, tracking at 150 FPS.
Daniel Gordon, Aniruddha Kembhavi, Mohammad Rastegari + 3 more
CVPR 2018
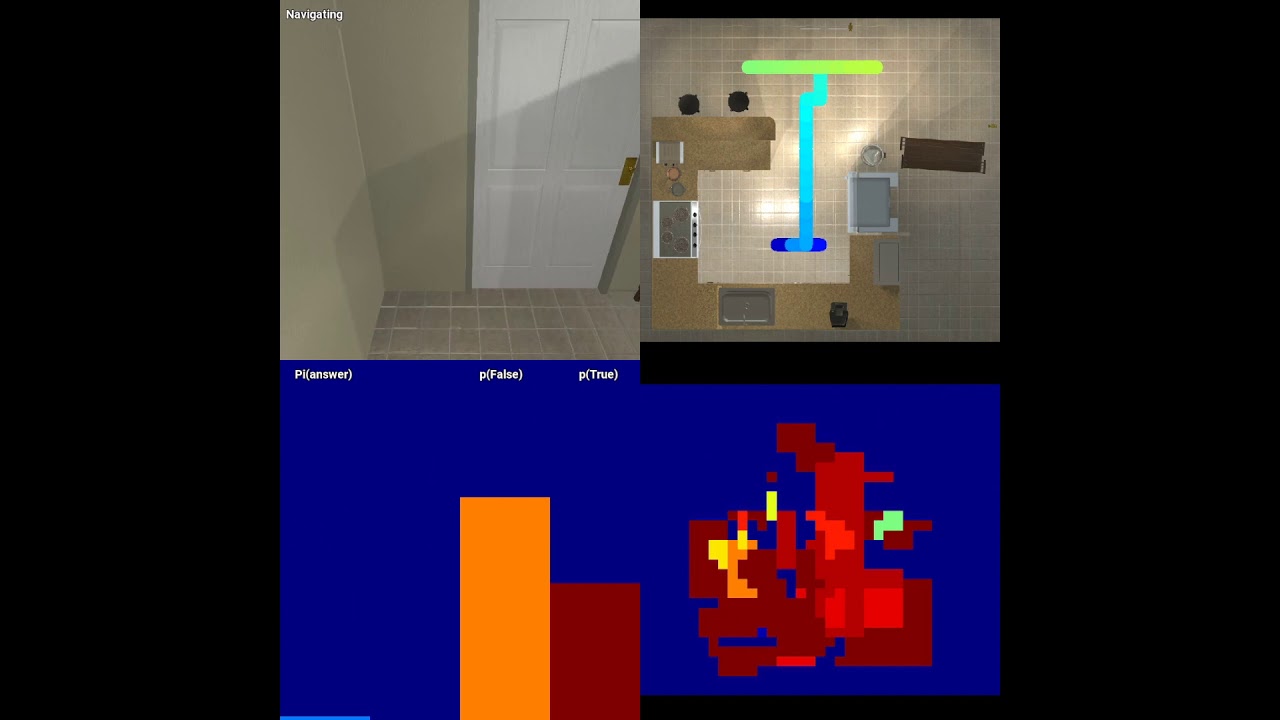
IQA asks questions that require both seeing and interacting with a scene. We develop the Hierarchical Interactive Memory Network to answer these questions with controllers at multiple levels of abstraction.
Eric Kolve, Roozbeh Mottaghi, Daniel Gordon + 9 more
AI2 TR 2017
AI2-THOR is a framework of procedurally generated synthetic 3D indoor scenes where agents navigate and interact, spanning RL, planning, question answering and detection.
Daniel Gordon*, Yuke Zhu*, Eric Kolve + 5 more
ICCV 2017
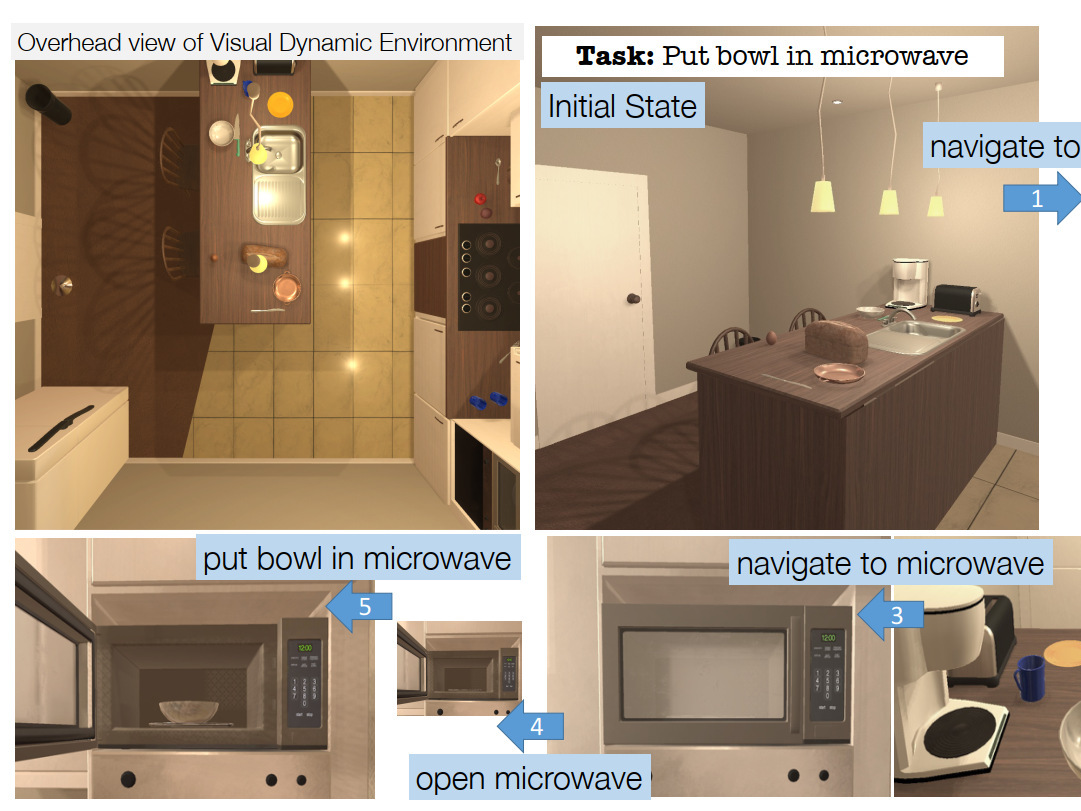
We develop the deep successor representation for decoupling perception and action in order to learn end-to-end policies that transfer to unseen items and environments.
Daniel Gordon
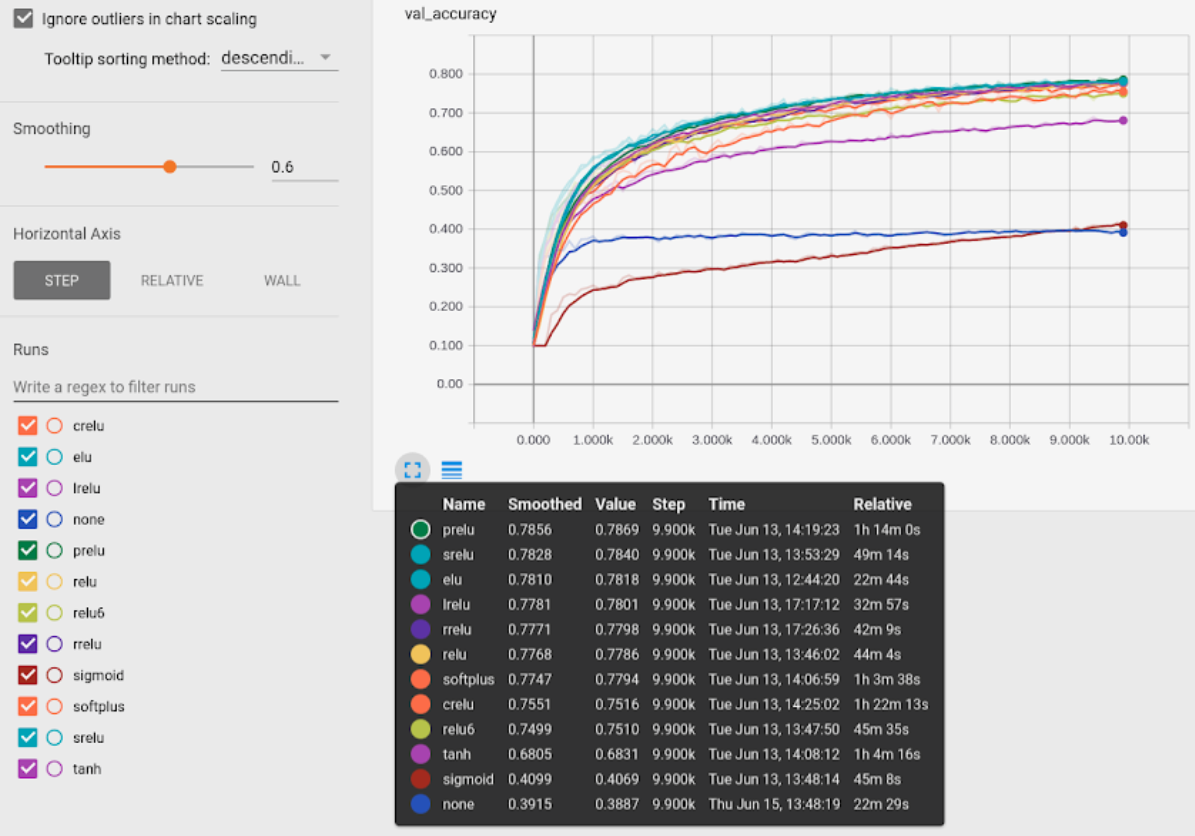
A seminar on applying modern deep learning to real research problems, including the unglamorous parts that decide whether a model ships.
Ruth West, Abby Halley, Jarlath O'Neil-Dunne + 2 more
IS&T/SPIE 2013
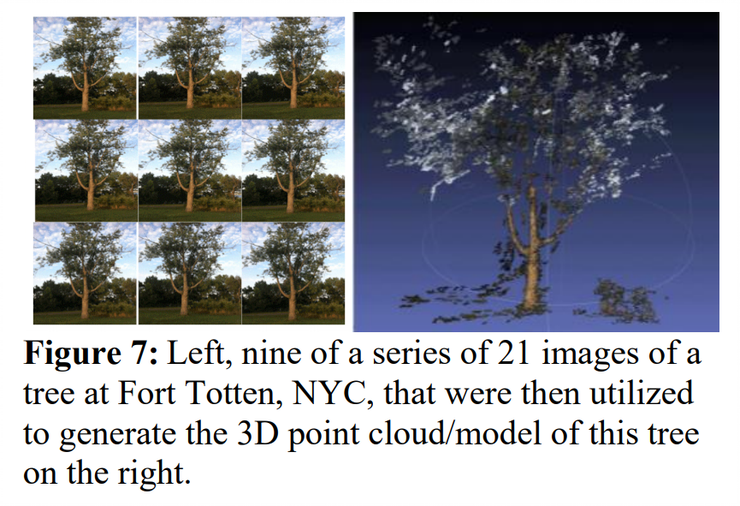
Augmented rephotography combined with LiDAR monitors the urban tree canopy, a community-based way to measure and visualize ecological change over time.
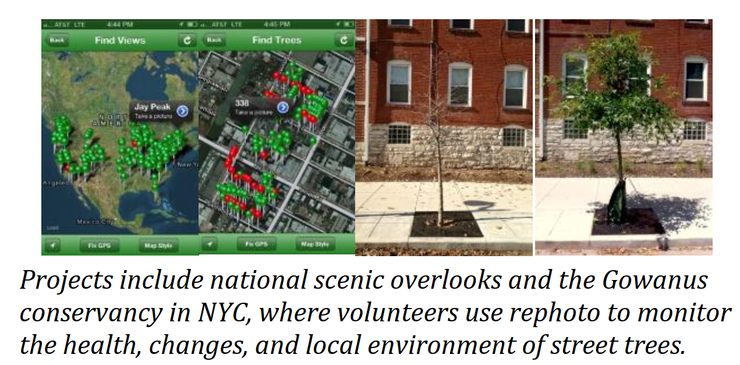
Ruth West, Abby Halley, Daniel Gordon + 2 more
SIGGRAPH 2013
Collaborative rephotography lets many people revisit many sites over time, from nation-scale scenic overlooks to NYC street trees.
Nothing matches those filters.
Try removing a topic.